Siemens PLC Snap7 Standard Command Description
This section introduces the standard interface commands based on Siemens Snap7 protocol (hereinafter referred to as S7 protocol).
Command Overview
RVS 2.0 S7 protocol supports the following standard commands:
Register Description
Field Name |
Type |
Offset/Address |
Description |
|---|---|---|---|
Command Trigger |
Bool |
0.0 |
Trigger signal |
Command |
Int |
2.0 |
Command code |
Pose Type |
Int |
4.0 |
Pose type |
Pose Number |
Int |
6.0 |
Expected vision point or path point count |
Vision Project No. |
Int |
8.0 |
Project number |
Recipe No. |
Int |
10.0 |
Parameter recipe number |
Flange Pose |
Array[0..5] of Real |
36.0 |
Flange pose data |
External Input Box Dimension |
Array[0..2] of Real |
68.0 |
Object dimensions passed into the RVS 2.0 project |
Index Counter |
Int |
108.0 |
Index count |
Index Name |
Int |
110.0 |
Index number |
Field Name |
Type |
Offset/Address |
Description |
|---|---|---|---|
Trigger Acknowledge |
Bool |
194.0 |
Trigger acknowledgment |
Status Code |
Int |
200.0 |
Status code |
Status of Pose Sent |
Bool |
202.0 |
Whether all vision points have been obtained |
Number of Pose Sent |
Int |
204.0 |
Number of vision points |
Target Pose |
Array[0..39, 0..5] of Real |
208.0 |
Poses of all vision points obtained this time |
Target Label |
Array[0..39] of Int |
1168.0 |
Labels of all vision points obtained this time |
Target Tool ID |
Array[0..39] of Int |
1248.0 |
End tool IDs of all vision points obtained this time |
Command Sending and Receiving
The robot or host computer, acting as the server, sends commands to the RVS 2.0 vision system, which acts as the client. After processing the command, the vision system returns the result to the robot or host computer.
Attention
The current version only supports this software running as an S7 client.
Command Data Units
RVS 2.0 software internally uses quaternions to represent poses, but they are automatically converted to Euler angle form during command communication.
A robot flange pose or robot tool pose consists of position and orientation. Position values (X, Y, Z) are measured in millimeters (mm), and orientation is expressed in Euler angles measured in degrees (°).
101 Command: Run RVS 2.0 Project
Description
This command starts the specified RVS 2.0 project. During execution, the vision system captures images, processes them, runs the configured algorithms, and then outputs a set of vision points.
Attention
Vision Point: The information unit used to describe a target object identified by the system. Each vision point contains the object’s pose, label, dimensions, and user-defined data.
Calling Sequence
Step parameters in the project need to be set before running the project. Therefore, 103 Command: Switch Parameter Recipe must be called before the 101 command.
Only after running the project can the vision system obtain vision points. Therefore, the 101 command must be called before 102 Command: Get Vision Results or 109 Command: Get User Label Data.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 101 |
Vision Project No. |
Int |
8.0 |
RVS 2.0 project number |
Pose Number |
Int |
6.0 |
Expected vision point count |
Pose Type |
Int |
4.0 |
Robot pose type |
Flange Pose |
Array[0..5] of Real |
36.0 |
Robot pose, Flange Pose is flange pose data |
Parameters
Parameter |
Description |
|---|---|
RVS 2.0 Project Number |
View in the project list window. The number before the project name is the number. |
Expected Vision Point Count |
Expected number of vision points to obtain: |
Robot Pose Type |
Specifies the input form of robot pose: |
Robot Pose |
Pass corresponding data according to “Robot Pose Type”. See the table below for details. |
Robot Pose Type and Pose Data Description
Robot Pose Format |
Description |
Applicable Scenario |
|
|---|---|---|---|
0 |
0,0,0,0,0,0 (placeholder, actually invalid) |
Do not pass robot pose to the vision system. |
Used when camera is Eye To Hand and project does not require pre-photo capture. |
2 |
Robot’s current flange pose |
Pass the robot’s current flange pose for the vision system to calculate camera position. |
Applicable to most scenarios, especially Eye In Hand camera mounting. |
Output Parameters
Field Name |
Type |
Offset/Address |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
If the command executes successfully, the status code is 1102; otherwise, the corresponding error code is returned. See RVS 2.0 Error Codes for details.
102 Command: Get Vision Results
Description
This command is used to obtain the vision results (a series of vision points) output after the RVS 2.0 project runs. The object poses in the vision points (corresponding to the Any port data of the “Vision Output” step) have been converted by the vision system to the corresponding robot tool poses.
Calling Sequence
This command must be called after the 101 Command: Run RVS 2.0 Project has successfully run the project and the 109 Command: Get User Label Data has been called. After this command is called to retrieve data, the data of the “Vision Output” step is cleared.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 102 |
Vision Project No. |
Int |
8.0 |
RVS 2.0 project number |
Index Counter |
Int |
108.0 |
Index count |
Index Name |
Int |
110.0 |
Index number |
RVS 2.0 Project Number
Must be consistent with the project number run in the 101 command.
Index Count and Index Number (Optional)
Specifies the count and numbers of vision points to obtain. Index starts from 0. For example, if there are currently 3 vision points and you want to obtain 2 this time, you can specify the desired combination by index number (for example, 0,1, 0,2, or 1,2).
Output Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
Status of Pose Sent |
Bool |
202.0 |
Whether all vision points have been obtained |
Number of Pose Sent |
Int |
204.0 |
Number of vision points |
Target Pose |
Array[0..39, 0..5] of Real |
208.0 |
Poses of all vision points obtained this time |
Target Label |
Array[0..39] of Int |
1168.0 |
Labels of all vision points obtained this time |
Target Tool ID |
Array[0..39] of Int |
1248.0 |
End tool IDs of all vision points obtained this time |
Parameters
Parameter |
Description |
|---|---|
Status Code |
1100: Execution successful; others are error codes. See RVS 2.0 Error Codes. |
Whether All Vision Points Have Been Obtained |
False: Not all vision points have been obtained. |
Vision Point Count |
Number of vision points returned this time. |
Poses of all vision points obtained this time |
Poses of all vision points obtained this time, in the form of robot tool poses. The vision system automatically converts the object pose of each vision point (that is, the Any port data of the “Vision Output” step) into the corresponding robot tool pose. |
Labels of all vision points obtained this time |
Labels of all vision points obtained this time. If there is no label information, the label value defaults to 0. |
End tool IDs of all vision points obtained this time |
End tool IDs of all vision points obtained this time. If none, it defaults to 0. |
103 Command: Switch Parameter Recipe
Description
This command is used to switch the parameter recipe used by the RVS 2.0 project.
Calling Sequence
This command must be called before 101 Command: Run RVS 2.0 Project.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 103 |
Vision Project No. |
Int |
8.0 |
RVS 2.0 project number |
Recipe No. |
Int |
10.0 |
Parameter recipe number |
The parameters are described below:
RVS 2.0 Project Number
Check the project list window; the number before the project name is the project number.
Parameter Recipe Number
Output Parameters
Field Name |
Type |
Offset/Address |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
If the command executes normally, the status code is 1107; otherwise, the corresponding error code is returned. See RVS 2.0 Error Codes for details.
109 Command: Get User Label Data
Description
This command is used to obtain the user label data defined by the RVS 2.0 project (that is, the input to the User Label pin of the Vision Output step).
Calling Sequence
This command must be called after the 101 Command: Run RVS 2.0 Project has successfully run the project, and before the 102 Command: Get Vision Results.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 109 |
Vision Project No. |
Int |
8.0 |
RVS 2.0 project number |
RVS 2.0 Project Number
Must be consistent with the project number run in the 101 command.
Output Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
Target Label |
Array[0..39] of Int |
1168.0 |
User label data obtained this time |
Status of Pose Sent |
Bool |
202.0 |
Whether all user label data has been obtained |
If the command executes normally, the status code is 1100; otherwise, the corresponding error code is returned. See RVS 2.0 Error Codes for details.
110 Command: Get Custom Data
Description
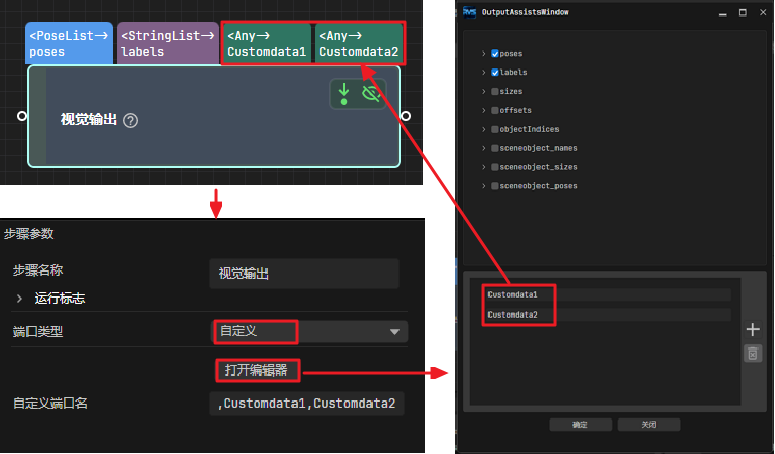
This command obtains custom port data from the “Vision Output” step and allows you to configure the input ports as needed.
Attention
The data from the preset ports shown at the top of the figure, such as
poses,labels,sizes, andoffsets, is predefined data, not custom data.The Port Type parameter of the “Vision Output” step must be set to “Custom”, and the
posesport is required.
Calling Sequence
This command must be called after 101 Command: Run RVS 2.0 Project.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 110 |
Vision Project No. |
Int |
8.0 |
RVS 2.0 project ID |
RVS 2.0 Project ID
You can check the ID of an RVS 2.0 project in the Project List panel. The number before the project name is its ID. Ensure that the Vision Project No. used in the 101 command is consistent with the project ID.
Output Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
Status of Pose Sent |
Bool |
202.0 |
Whether all vision points have been obtained |
Target Pose |
Array[0..39, 0..5] of Real |
208.0 |
Poses of all vision points obtained this time |
Target Label |
Array[0..39] of Int |
1168.0 |
Labels of all vision points obtained this time |
Custom Vision Output |
Array[0..39, 0..9] of Real |
1456.0 |
Custom data of all vision points obtained this time |
Status Code
Status code 1100 is returned on successful command execution. On failure, the corresponding error code is returned. See RVS 2.0 Error Codes for details.
Status of Pose Sent
This parameter indicates whether all vision points have been obtained. The value is False or True.
False: Not all vision points are obtained.
True: All vision points are obtained.
Target Pose
This parameter indicates the poses of all vision points obtained this time. The vision system automatically converts the object pose of each vision point (that is, the data from the poses port of the “Vision Output” step) into the corresponding robot tool pose. The conversion process is as follows:
Convert the object pose from quaternion form to Euler angles.
Rotate the object pose 180° around the X-axis so that its Z-axis points downward.
Target Label
This parameter indicates the labels of all vision points obtained this time.
Note
The label must be a string in integer format.
If there is no label information, the label value defaults to 0.
Custom Vision Output
Custom data of all vision points obtained this time. The custom data items are arranged in alphabetical order by custom port name.
For example, if the data output from the ports of the “Vision Output” step is as shown in the table below, the robot obtains [0, 0, 1] and [0, 0] for the custom data items of the first vision point, and [1, 0, 0] and [1, 1] for those of the second vision point.
Port Name |
poses |
labels |
Custom Data 1 |
Custom Data 2 |
|---|---|---|---|---|
Port Data |
[ |
[ |
[ |
[ |
[0, 0, 0, 1, 0, 0, 0], |
“0”, |
[0, 0, 1], |
[0, 0], |
|
[0, 0, 0, 1, 0, 0, 0], |
“1” |
[1, 0, 0] |
[1, 1] |
|
] |
] |
] |
] |
|
First vision point |
[0, 0, 0, 1, 0, 0, 0] |
0 |
[0, 0, 1] |
[0, 0] |
Second vision point |
[0, 0, 0, 1, 0, 0, 0] |
1 |
[1, 0, 0] |
[1, 1] |
501 Command: Input Object Dimensions into an RVS 2.0 Project
Description
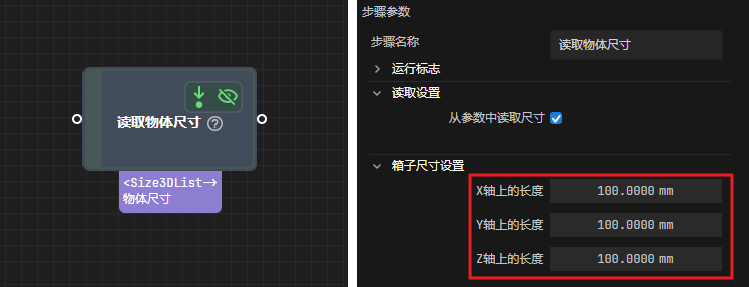
This command inputs object dimensions into an RVS 2.0 project. The input dimensions are the values of the Box Size Settings parameters of the “Read Object Dimensions” step, as shown below.
Attention
When using this command, only one “Read Object Dimensions” step is allowed in an RVS 2.0 project. Otherwise, the vision system returns an error.
Calling Sequence
This command must be called before 101 Command: Run RVS 2.0 Project.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 501 |
Vision Project No. |
Int |
8.0 |
RVS 2.0 project ID |
External Input Box Dimension |
Array[0..2] of Real |
68.0 |
Object dimensions (length, width, height) to be input into the RVS 2.0 project |
Vision Project No.
You can check the ID of an RVS 2.0 project in the Project List panel. The number before the project name is its ID. Ensure that the Vision Project No. used in the 101 command is consistent with the project ID.
External Input Box Dimension
The length, width, and height of the object, in millimeters (mm). The values are read by the “Read Object Dimensions” step and written to the Length on X-axis, Length on Y-axis, and Length on Z-axis parameters respectively.
Output Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
Status Code
Status code 1108 is returned on successful command execution. On failure, the corresponding error code is returned. See RVS 2.0 Error Codes for details.
901 Command: Get System Status
Description
This command checks whether the RVS 2.0 vision system is ready, including the RVS 2.0 status and the camera status.
Input Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Command |
Int |
2.0 |
Command code is 901 |
Output Parameters
Name |
Data Type |
Offset |
Description |
|---|---|---|---|
Status Code |
Int |
200.0 |
Status code |
Status Code
Status code 1101 is returned on successful command execution. On failure, the corresponding error code is returned. See RVS 2.0 Error Codes for details.