Convert 2D Points to 3D Points
Function Description
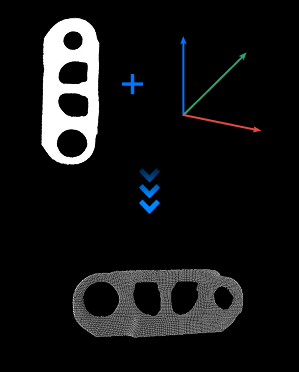
Projects pixel points from 2D images into a virtual plane defined by a specified camera pose in 3D space, generating a single-layer 3D point cloud.
Use Cases
This step is typically used when 2D shape features need to be matched in 3D, for example by converting 2D edges into a 3D point cloud for downstream matching.
Inputs
Images: Single or multiple 2D mask images.
Poses: Plane pose of the 2D image, used to specify the spatial plane where the 3D point cloud is generated.
Outputs
Point Clouds: 3D point cloud converted from the input 2D image.