Project 3D Point Cloud to 2D Image
Function Description
Based on the perspective projection model (camera model), converts the input 3D point cloud into a 2D depth image or mask image.
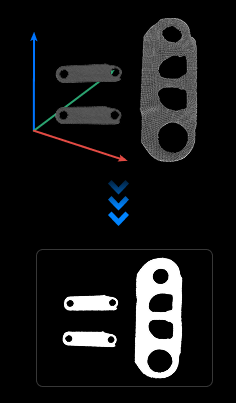
Use Cases
Used in the point cloud preprocessing stage. First converts the 3D point cloud into a 2D image, uses 2D image processing methods (such as 2D morphology or depth map processing operations), and then converts back to point cloud through steps like converting depth map to point cloud.
Inputs and Outputs
Input: Point cloud with normals.
Attention
Converting point cloud to 2D image requires camera intrinsic matrix. Therefore, the input point cloud must come from the depth map or point cloud output by the “Image Acquisition” step (real or virtual camera). Local point cloud files imported through the “Read Point Cloud” step are not supported.
Output: Mask/Depth Image.
The output type is determined by the image type parameter:
Mask: Converts 3D point cloud to mask image and outputs.
Depth: Converts 3D point cloud to depth image and outputs.
Parameters
Image Type
This parameter is used to specify the type of output image:
Mask: Converts 3D point cloud to mask image and outputs.
Depth: Converts 3D point cloud to depth image and outputs.