Point Cloud Clustering
Function Description
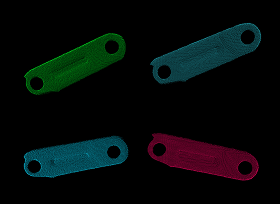
This step can perform point cloud clustering according to specified rules, commonly used for segmentation of target objects.
Use Cases
This step is generally used for point cloud preprocessing to eliminate mutual interference between object point clouds.
Inputs
Point Cloud with Normals: Point cloud to be clustered.
Classification Labels: Classification labels corresponding to the input point cloud.
Outputs
Clustered Point Cloud: Point cloud after clustering.
Classification Labels: Classification labels corresponding to the output point cloud.
Parameters
Clustering Algorithm This parameter is used to select the clustering method.
Value list: EuclideanCluster, RegionGrowingSeg
EuclideanCluster: Euclidean clustering, calculates the distance between the current point and all other points, and determines whether point clouds belong to the same class based on distance.
RegionGrowingSeg: Region growing segmentation, calculates the distance between the current point and points within the neighborhood range, and determines whether point clouds belong to the same class based on distance.
Maximum Distance Between Adjacent Points in Output Class
This parameter is used to set the maximum distance between points in the same class. Points with spacing smaller than this distance will be classified as the same class.
Neighborhood Radius
This parameter is used to set the size of the neighborhood range in the region growing segmentation algorithm, using this pixel radius as the adjacent region range. The larger this value, the more points in the neighborhood, and the sparser the clustering results.
Minimum Point Count per Class / Maximum Point Count per Class
This parameter is used to filter clustering results. Point clouds will only be output when their point count is between the minimum point count and maximum point count after clustering.
Default values: 800/3000000
Adjustment example: Suppose the point counts of point clouds after clustering are 10000, 20000, 30000, 40000, 50000 respectively. If the maximum point count per class is 45000 and the minimum point count per class is 15000, then classes with point counts of 10000 and 50000 will be filtered out, and only point clouds with point counts of 20000, 30000, and 40000 will be output.