Transform Point Clouds
Function Description
This step can transform point clouds from one coordinate system to another, or perform position transformation within its own coordinate system based on reference poses.
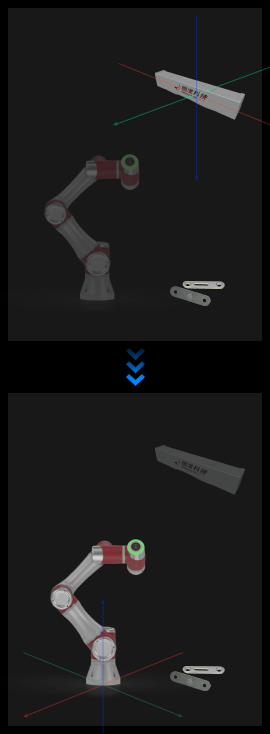
Use Cases
This step is generally used for transformation between camera coordinate system and robot coordinate system for point clouds.
Inputs
Point Cloud (Required): Original point cloud to be transformed.
Outputs
Point Cloud: Transformed point cloud.
Parameters
Transformation Settings
Transformation Type
Sets the transformation method for point clouds.
CameraToRobot: Transforms point clouds from camera coordinate system to robot coordinate system.
RobotToCamera: Transforms point clouds from robot coordinate system to camera coordinate system.
AllWithFirst: Transforms the original point cloud to the coordinate system of the reference pose based on the first pose in the input reference pose list.
FirstWithAll: Transforms the first point cloud in the original point cloud list to the coordinate systems of each reference pose respectively based on all poses in the input reference pose list.
OneWithOne: One-to-one transformation. Each point cloud in the original point cloud list is sequentially transformed to the coordinate system of the corresponding pose in the reference pose list (requires the number of input point clouds to equal the number of reference poses).
AffineTransform: Transforms point clouds through affine transformation matrix. You can use the “Convert PoseList to Matrix4D” step to convert poselist to matrix4D, and then input it to the Matrix4D input port of this step.