Create Point Cloud Model from Camera Data
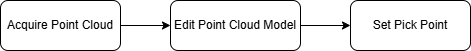
In this workflow, the camera is used to acquire the point cloud, from which a point cloud model is generated and pick points are manually set.
The overall operation process is shown in the figure below.
Preparations
To acquire the point cloud in this workflow, use the “ImageAcquisition” step of a project in the current solution. Ensure that the selected project is correctly connected to a real camera, the camera’s field of view fully covers the target object (or its feature areas), and the camera parameters have been adjusted to the expected state, so that the point cloud acquisition quality is guaranteed.
Acquire Point Cloud
The first step after entering the operation flow is to acquire the point cloud. The specific steps are as follows:
Set Project Information and Acquire Point Cloud
In the Project Information area, select the project and camera to use. By default, the first project that contains the “ImageAcquisition” step and is connected to a real camera is selected automatically.
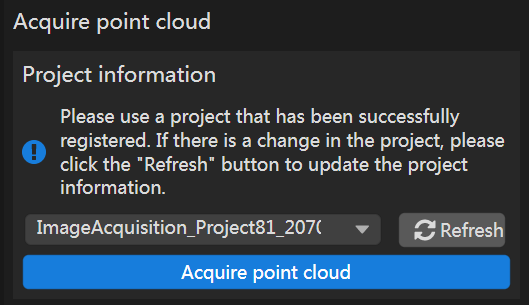
Click the
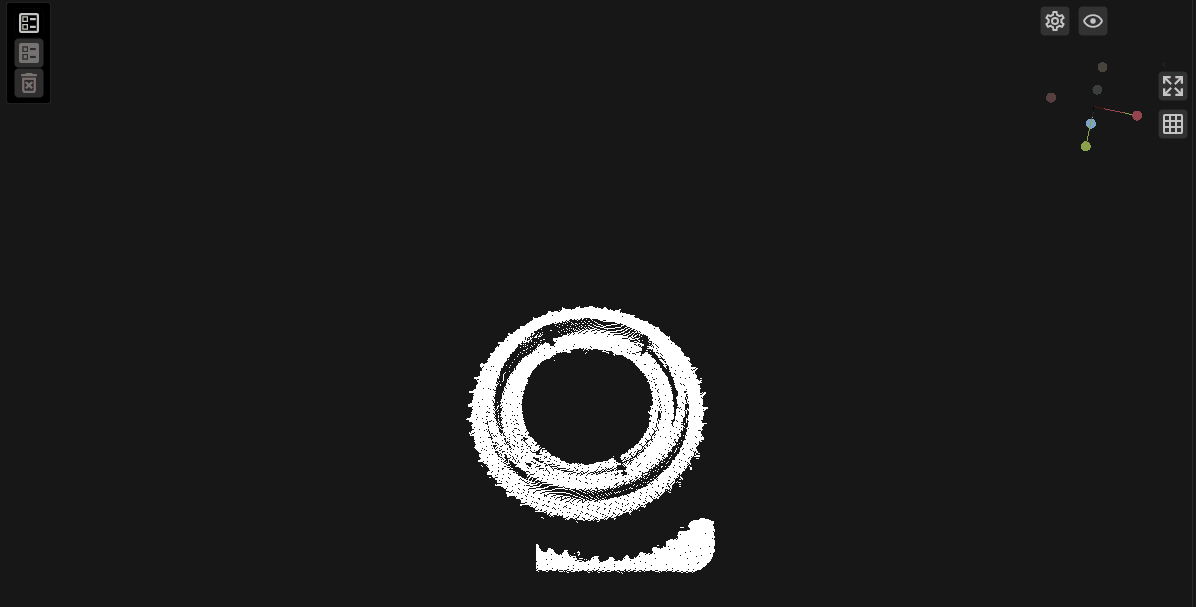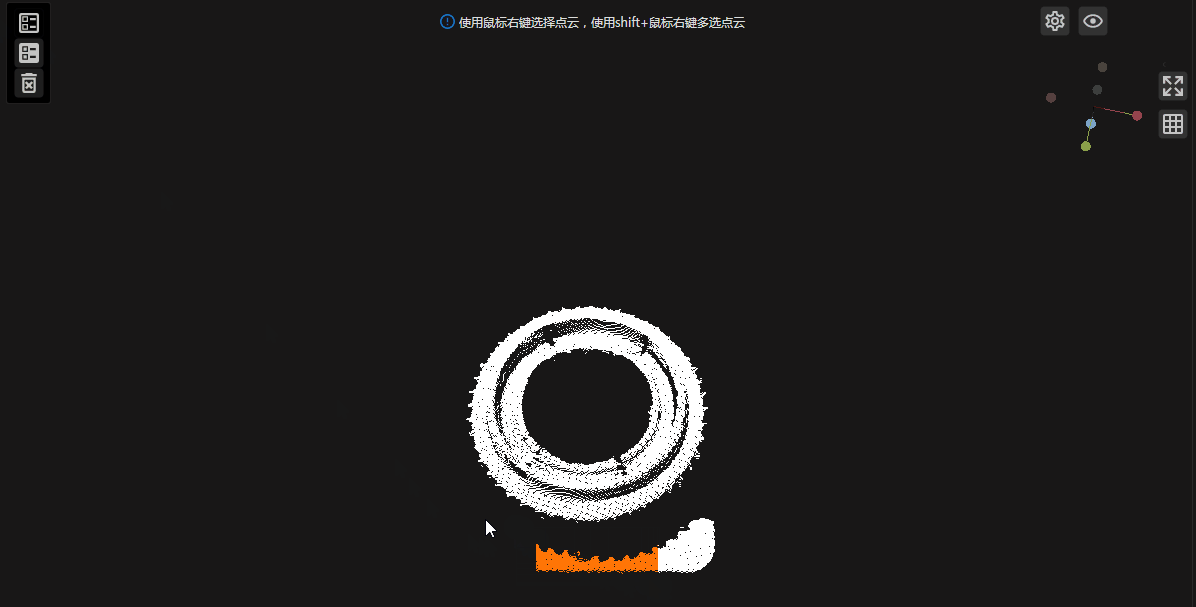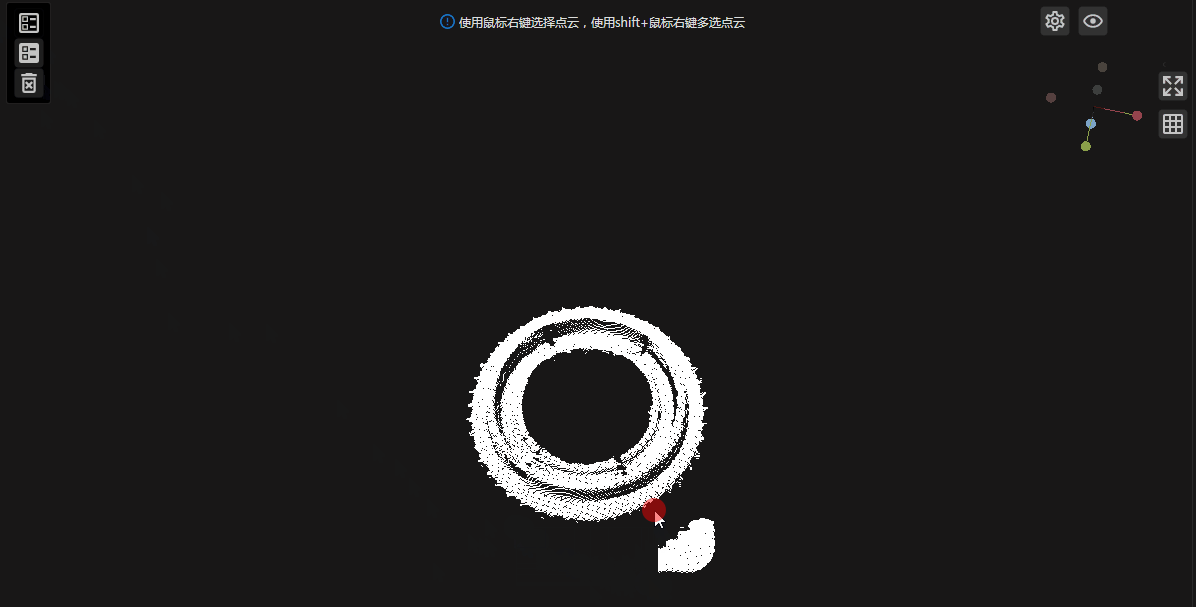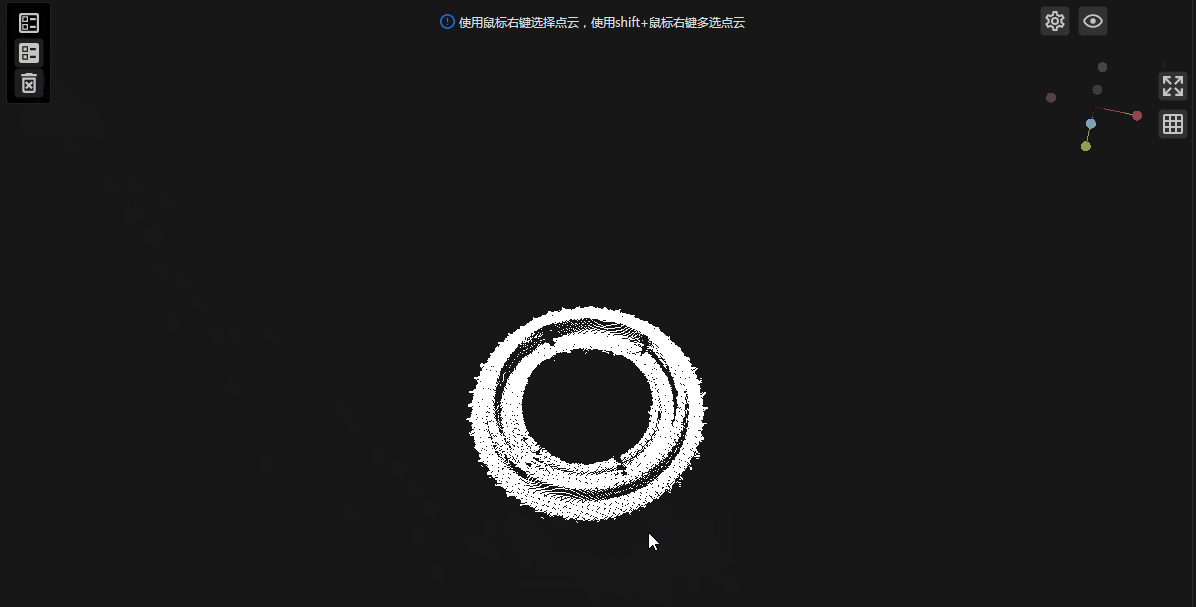
Acquire point cloudbutton.The acquired point cloud will appear in the point cloud display area in the center of the interface.
Set 3D ROI (Optional)
To quickly remove irrelevant point clouds from the scene and extract the target object point cloud, enable the “Remove irrelevant point cloud using 3D ROI” option.
After the option is enabled, a 3D ROI box appears in the point cloud display area. Adjust the position and size of the box to define the valid region of the target object. For detailed instructions, see Adjust the ROI.
Set Edge Point Cloud Estimation Method
The edge point cloud estimation method is used to estimate the point cloud at the target object edges to assist subsequent model editing and pick point settings. The system provides two methods:
2D
The 2D method for estimating point cloud edges is based on edge detection of RGB images acquired by the camera to extract edge point clouds. Applicable when target object edges have obvious features in RGB images.
For specific parameter explanations, see 2D Edge Point Cloud Estimation.
3D
The 3D method for estimating point cloud edges is based on edge detection of point clouds acquired by the camera to extract edge point clouds. Applicable when target object edges are not obvious in RGB images but have obvious features in point cloud data.
For specific parameter explanations, see 3D Edge Point Cloud Estimation.
Edit Model
When generating a model from point clouds acquired by the camera, ensure that the point cloud accurately reproduces the target object features and that all interfering point clouds are removed.
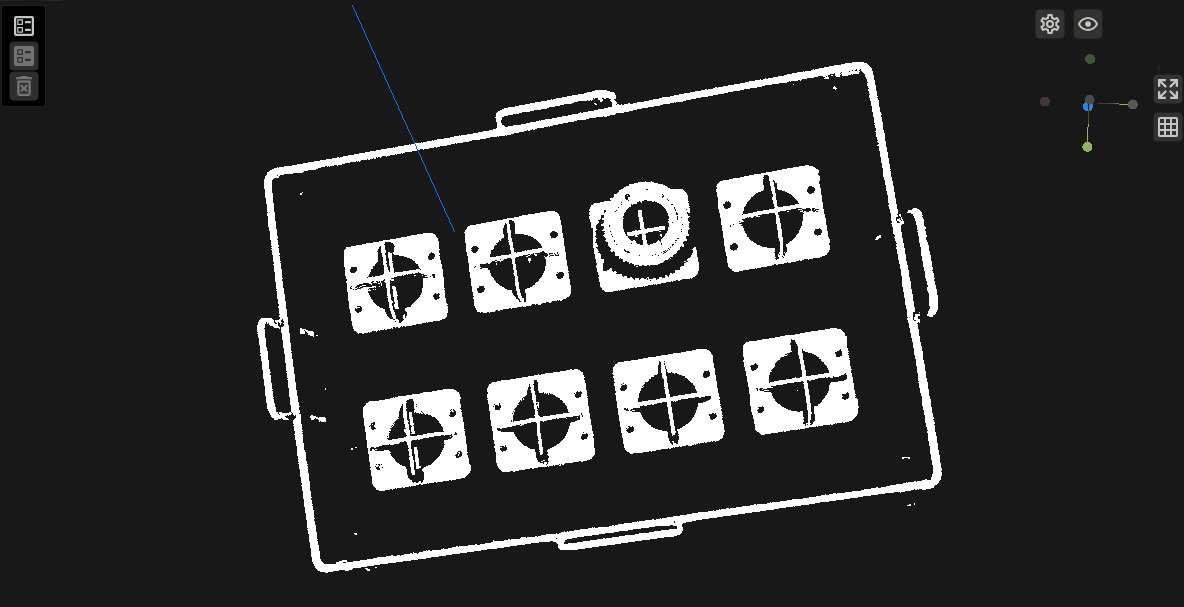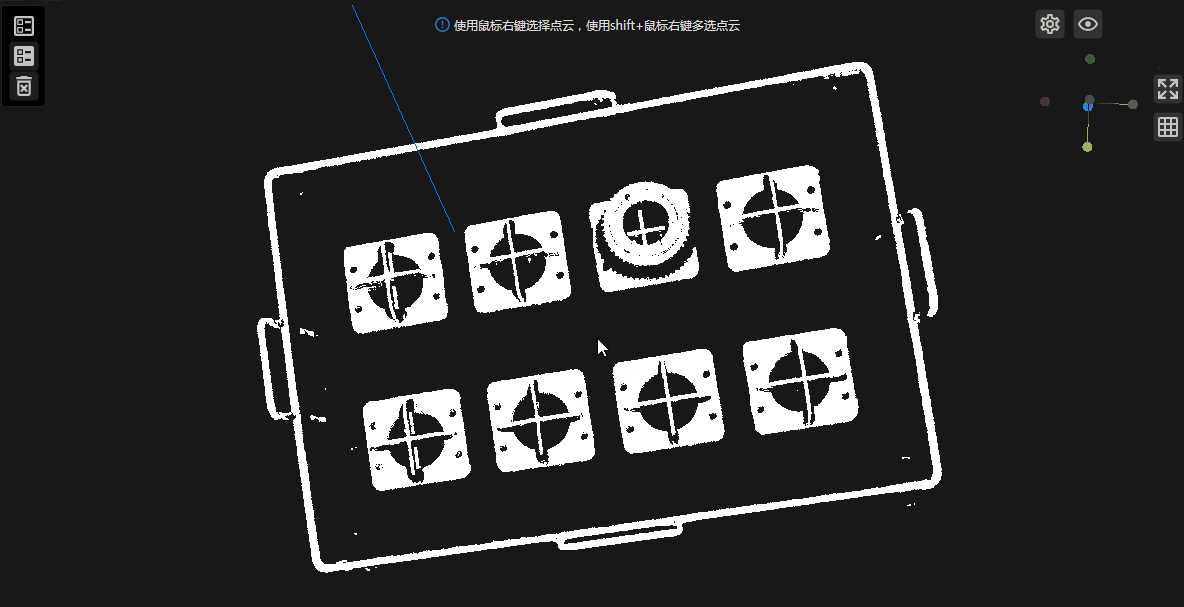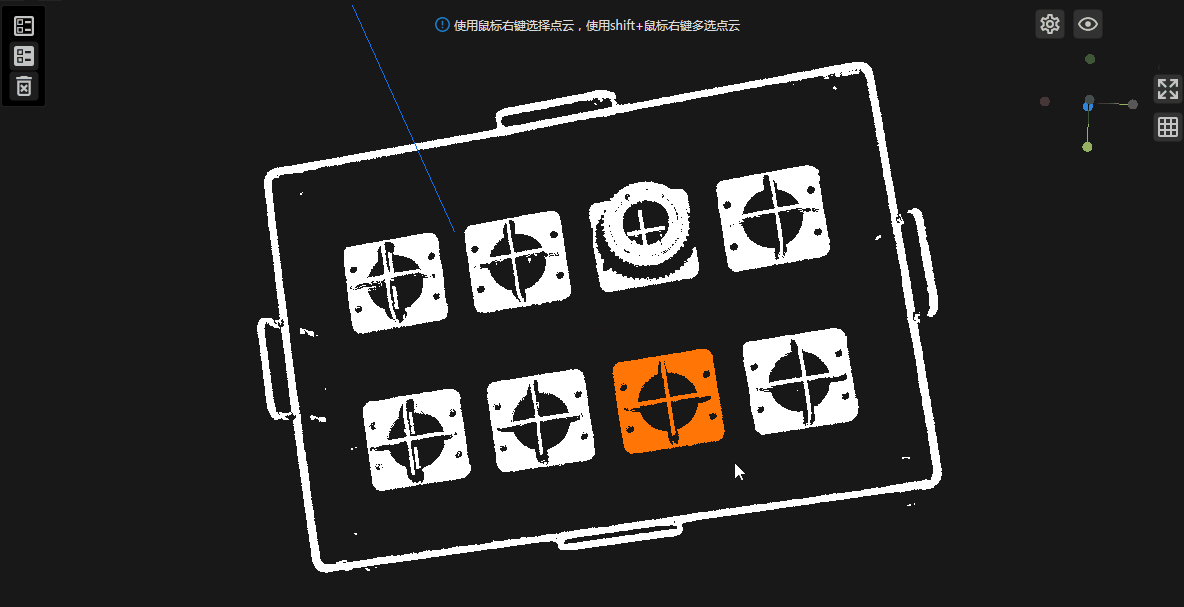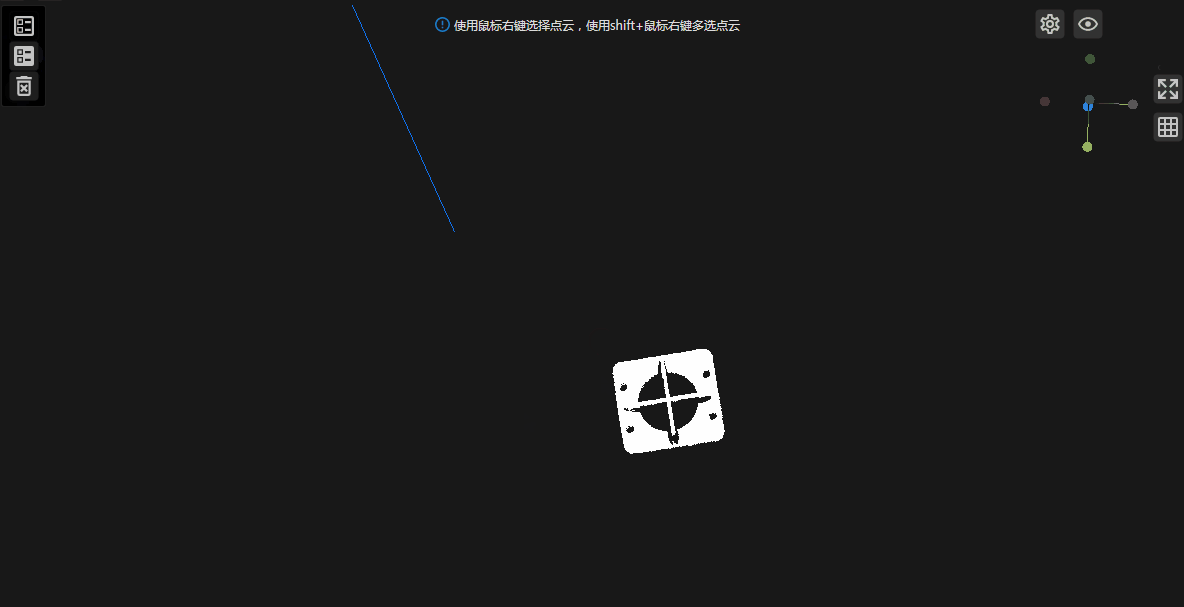
Extract Target Object Point Cloud for the Model
You can use the following two methods to extract the target object point cloud:
Directly Select Point Cloud and Delete
Applicable when there are few interfering point clouds.
Click
 to enter point cloud selection mode.
Use the right mouse button to select irrelevant point clouds, or use
Shift+ right mouse button for multi-select.Click
 to delete the selected interfering point clouds.
Invert Selection and Delete
Applicable when there are many interfering point clouds and the target object point cloud is easier to select.
Click
to enter point cloud selection mode.Use the right mouse button to select target object point clouds, or use
Shift+ right mouse button for multi-select.Click
 to invert the selection. At this time, non-target-object point clouds will be selected.
Click
to delete the selected interfering point clouds.
Calibrate Object Center Point
Calibrate the center point position of the target object according to its actual usage.
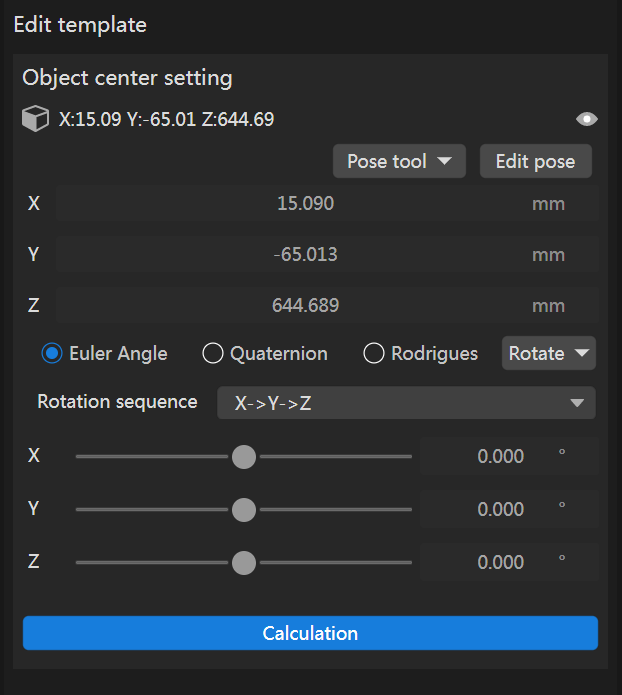
The following two calibration methods are supported:
Recalculate Using Original Center Point
Click the
Calculationbutton, and the system will automatically recalculate the target object center point based on the geometric features of the target object and the original center point.Manually Set Object Center Point Pose
You can manually set the pose using the following methods:
Modify Directly in the Configuration Panel: In the Object center setting panel, directly adjust the coordinates (X, Y, Z) and rotation parameters.
Adjust Pose Offset Using the Pose Transform Tool: Click the
Pose toolbutton to open the Transform Pose tool. Adjust the offset relative to the current position and orientation to update the pose in real time. The 3D pose control in the interface updates accordingly.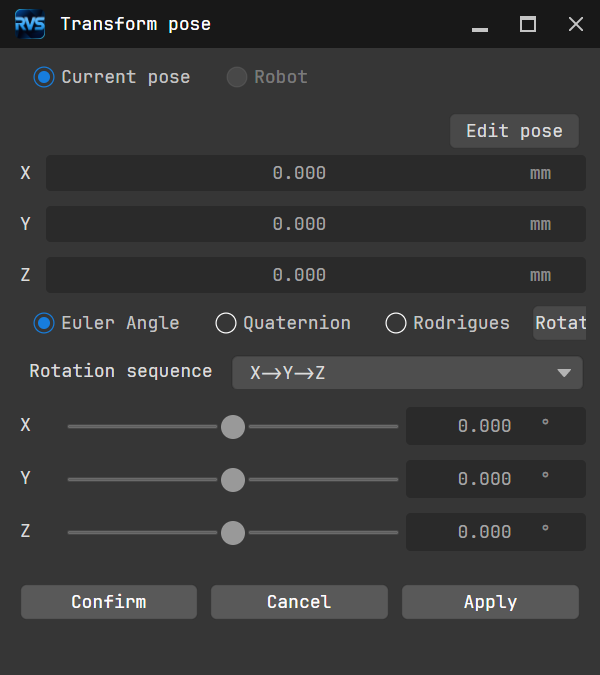
Input Through the Pose Edit Interface: Click the
Edit Posebutton and directly input position and rotation information in the pop-up window according to the indicated format. After clickingConfirm, the input values will be synchronized to the Object center setting panel.
Set Pick Points
Click “+New” in the Config pick points panel to add pick points on the edited target object model. The newly created pick point’s default position coincides with the target object center set in the Calibrate Object Center Point step. You can manually adjust the pick point pose through the Pick Point Configuration panel.
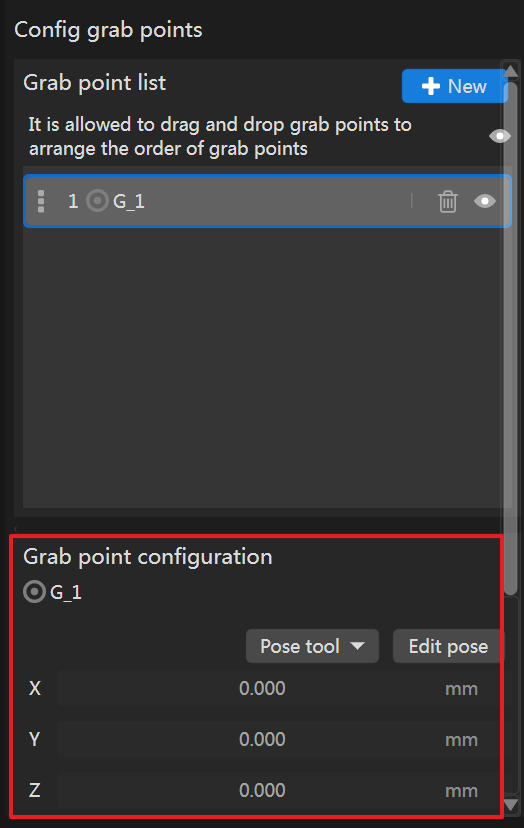
You can manually set the pose using the following methods:
Modify Directly in the Configuration Panel: In the Pick point configuration panel, directly adjust the coordinates (X, Y, Z) and rotation parameters.
Adjust Pose Offset Using the Pose Transform Tool: Click the
Pose toolbutton to open the Transform Pose tool. Adjust the offset relative to the current position and orientation to update the pose in real time. The Pick point configuration panel updates accordingly.Input Through the Pose Edit Interface: Click the
Edit posebutton and directly input position and rotation information in the pop-up window according to the indicated format. After clickingConfirm, the input values will be synchronized to the Pick point configuration panel.
Save Model
Click the Save button in the lower-right corner to save the current model and pick points. Saved target object models appear in the Target Object List on the left side of the interface.