Calculate Pose and Dimensions from Planar Point Cloud
Function Description
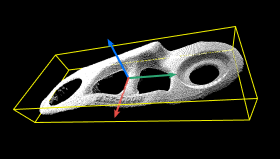
Calculates the pose of planar point clouds and the bounding box dimensions of the point cloud.
Use Cases
This step is typically used to calculate grasping points and dimensions for planar objects such as cartons and bags. Before using this step, point clouds should be filtered and clustered to reduce the impact of noise on results.
Inputs
Point Cloud with Normals (Required): Point cloud with normals to be processed.
Reference Pose (Optional): Ground pose. When connected, the “height” of the box dimensions can be calculated.
Outputs
Point Cloud Pose: The calculated point cloud pose.
Box Dimensions: The bounding box dimensions of the point cloud.
Parameters
Attention
The method for calculating pose center and the method for calculating pose orientation must correspond one-to-one:
BoundingRectCenter corresponds to BoundingRectOrientation
CloudCenter corresponds to CloudOrientation
Method for Calculating Pose Center
This parameter is used to select the method for calculating the point cloud pose center.
BoundingRectCenter: Uses the geometric center of the point cloud’s minimum bounding box as the output point cloud pose center. Recommended when the point cloud distribution of the object is relatively uniform.
CloudCenter: Uses the centroid of the point cloud (the arithmetic mean of all point coordinates) as the output point cloud pose center. Recommended when the point cloud distribution of the object is uneven.
Method for Calculating Pose Orientation
This parameter is used to specify the pose orientation.
BoundingRectOrientation: Uses the orientation of the point cloud’s minimum bounding box as the output point cloud pose orientation. Recommended when the point cloud distribution of the object is relatively uniform.
CloudOrientation: Uses the orientation of the point cloud’s centroid as the output point cloud pose orientation. Recommended when the point cloud distribution of the object is uneven.