Robot and Communication Configuration
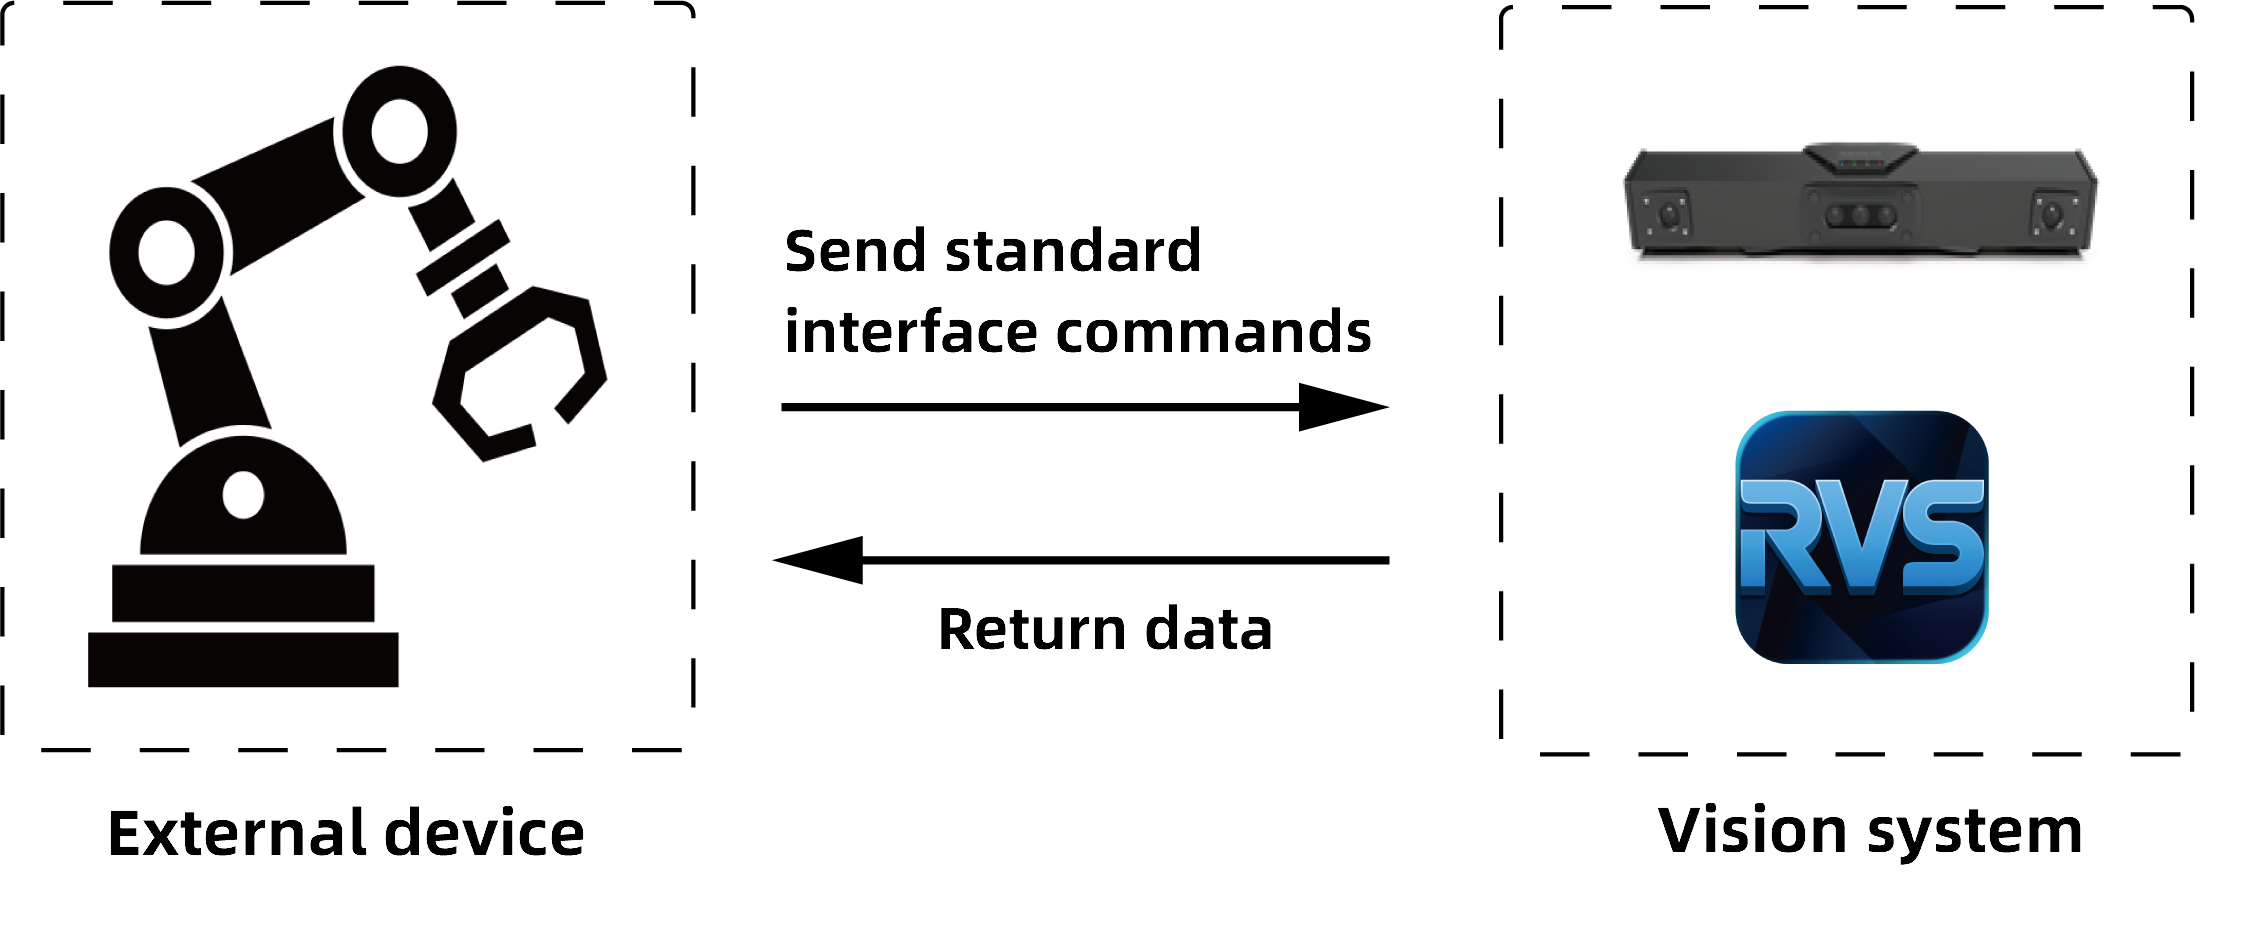
The vision system needs to establish communication with external devices (such as robots) to achieve data exchange. RVS 2.0 uses Standard Interface Communication mode: external devices send standard commands, and the vision system receives them and returns corresponding results.
In this mode, the vision system passively responds to external device commands. Users need to write their own external device programs to complete communication interaction.
The system supports two communication protocols: TCP Server and Siemens Snap7 Client.
Related documentation:
Configure Communication: Learn how to configure and start the communication service.
TCP Standard Command Description: TCP command usage.
S7 Standard Command Description: Siemens Snap7 command usage.
Standard Interface Status Code List: Standard interface communication status code reference.